In a helicopter, an autorotative descent is a power-off maneuver in which the engine is disengaged from the main rotor disk and the rotor blades are driven solely by the upward flow of air through the rotor. [Figure 1] In other words, the engine is no longer supplying power to the main rotor.
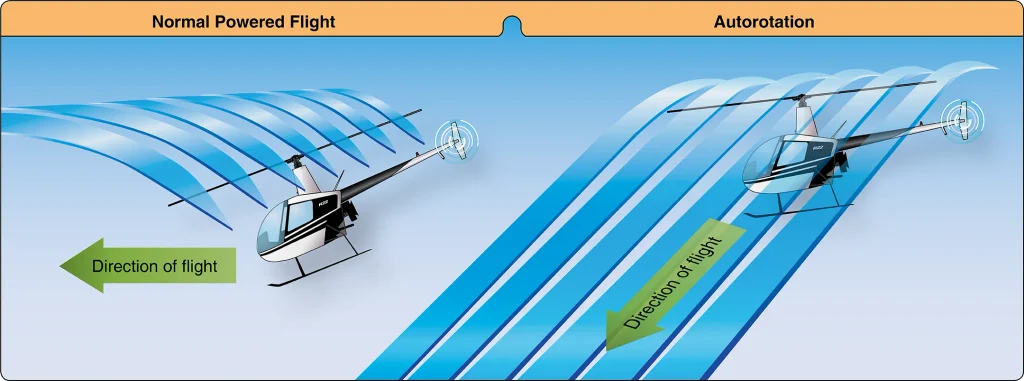
If the engine fails, the freewheeling unit automatically disengages the engine from the main rotor, allowing it to rotate freely. Essentially, the freewheeling unit disengages anytime the engine revolutions per minute (rpm) is less than the rotor rpm.
At the instant of engine failure, the main rotor blades are producing lift and thrust from their angle of attack (AOA) and velocity. By lowering the collective (which must be done immediately in case of an engine failure), lift and drag are reduced, and the helicopter begins an immediate descent, thus producing an upward flow of air through the rotor disk. This upward flow of air through the rotor disk provides sufficient thrust to maintain rotor rpm throughout the descent. Since the tail rotor is driven by the main rotor transmission during autorotation, heading control is maintained with the antitorque pedals as in normal flight.
Several factors affect the rate of descent in autorotation: bank angle, density altitude, gross weight, rotor rpm, trim condition, and airspeed. The primary ways to control the rate of descent are with airspeed and rotor rpm. Higher or lower airspeed is obtained with the cyclic pitch control just as in normal powered flight. In theory, a pilot has a choice in the angle of descent, varying, from straight vertical to maximum horizontal range (which is the minimum angle of descent). Rate of descent is high at zero airspeed and decreases to a minimum at approximately 50–60 knots, depending upon the particular helicopter and the factors just mentioned. As the airspeed increases beyond that which gives minimum rate of descent, the rate of descent increases again.
When landing from an autorotation, the only energy available to arrest the descent rate and ensure a soft landing is the kinetic energy stored in the rotor blades. Tip weights can greatly increase this stored energy. A greater amount of rotor energy is required to stop a helicopter with a high rate of descent than is required to stop a helicopter that is descending more slowly. Therefore, autorotative descents at very low or very high airspeeds are more critical than those performed at the minimum rate of descent airspeed. Refer to the height/velocity diagram discussion in Helicopter Performance section.
Each type of helicopter has a specific airspeed and rotor rpm at which a power-off glide is most efficient. The specific airspeed is somewhat different for each type of helicopter, but certain factors affect all configurations in the same manner. In general, rotor rpm maintained in the low green area (see Figure 2) gives more distance in an autorotation.
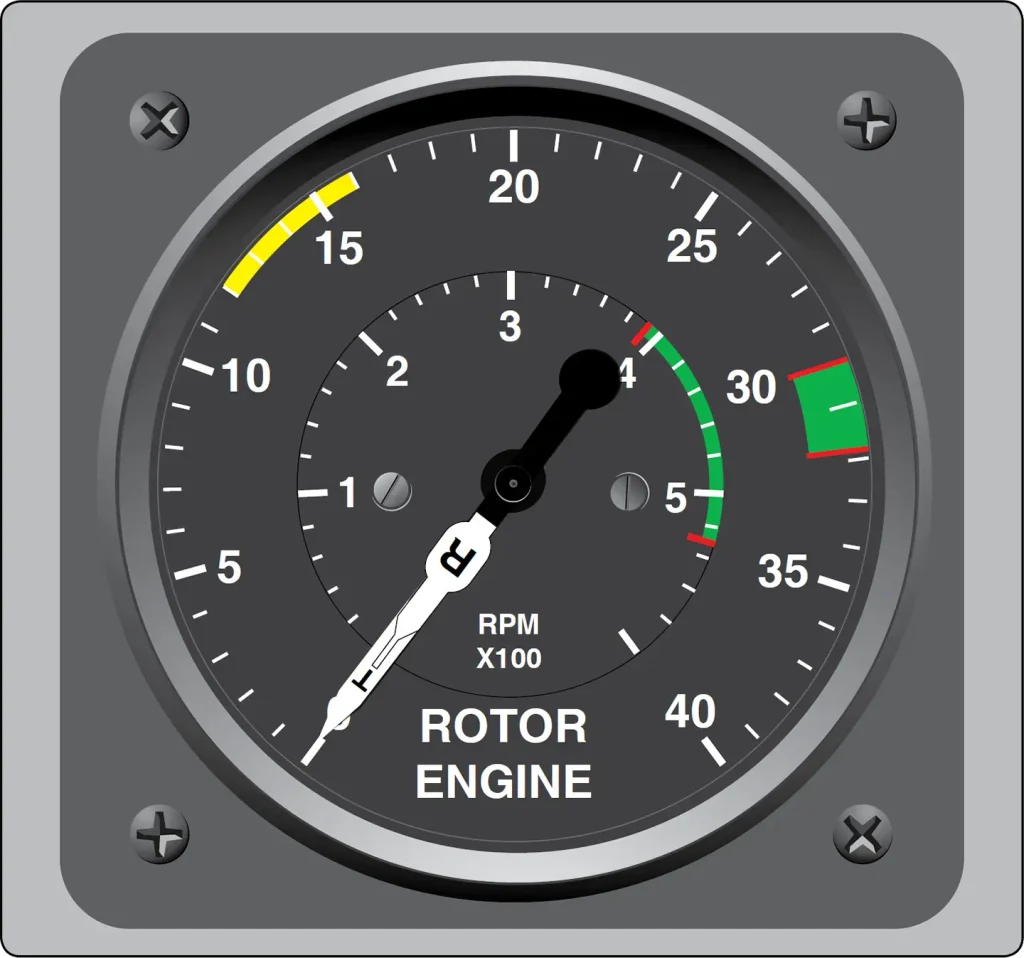
Heavier helicopter weights may require more collective to control rotor rpm. Some helicopters need slight adjustments to minimum rotor rpm settings for winter versus summer conditions, and high altitude versus sea level flights. For specific autorotation airspeed and rotor rpm combinations for a particular helicopter, refer to the Rotorcraft Flight Manual (RFM). The specific airspeed and rotor rpm for autorotation is established for each type of helicopter based on average weather, calm wind conditions, and normal loading. When the helicopter is operated with heavy loads in high density altitude or gusty wind conditions, best performance is achieved from a slightly increased airspeed in the descent. For autorotation at low density altitude and light loading, best performance is achieved from a slight decrease in normal airspeed. Following this general procedure of fitting airspeed and rotor rpm to existing conditions, a pilot can achieve approximately the same glide angle in any set of circumstances, and thereby estimate the touchdown point accurately.
It is important that pilots experience autorotations from various airspeeds. This provides better understanding of the necessary flight control inputs to achieve the desired airspeed, rotor rpm and autorotation performance, such as the maximum glide or minimum descent airspeed. The decision to use the appropriate airspeed and rotor rpm for the given conditions should be instinctive to reach a suitable landing area. The helicopter glide ratio is much less than that of a fixed-wing aircraft and takes some getting used to. The flare to land at 80 knots indicated airspeed (KIAS) will be significantly greater than that from 55 KIAS. Rotor rpm control is critical at these points to ensure adequate rotor energy for cushioning the landing.
Use collective pitch control to manage rotor rpm. If rotor rpm builds too high during an autorotation, raise the collective sufficiently to decrease rpm back to the normal operating range, then reduce the collective to maintain proper rotor rpm. If the collective increase is held too long, the rotor rpm may decay rapidly. The pilot would have to lower the collective in order to regain rotor rpm. If the rpm begins decreasing, the pilot must again lower the collective. Always keep the rotor rpm within the established recommended range for the helicopter being flown.
RPM Control
Rotor rpm in low inertia rotor systems has been studied in simulator flight evaluations which indicate that the simultaneous application of aft cyclic, down collective, and alignment with the relative wind (trim) at a wide range of airspeeds, including cruise airspeeds, is critical for all operations during the entry of an autorotation. The applicable Rotorcraft Flight Manual (RFM) should be consulted to determine the appropriate procedure(s) for safely entering an autorotation. This is vitally important since the procedure(s) for safely entering an autorotation may vary with specific makes and/or models of helicopters. A basic discussion of the aerodynamics and control inputs for single rotor systems is in order here.
Helicopter pilots must understand the use of the collective for rotor rpm control during power off autorotations in a turn. Upward movement of the collective reduces the rpm and downward movement increases the rpm. Cyclic movement is primarily associated with attitude/airspeed control in powered flight but may not be given the credit appropriate for rotor rpm control during practice and emergency power off autorotations. As long as the line of cyclic movement is parallel with the flight path of the helicopter (trimmed), the aft movement of the cyclic also creates greater air flow up through the bottom of the rotor disk and contributes to an increase in rotor rpm. If the flight path is 10 degrees to the right of the longitudinal axis of the helicopter, theoretically, the cyclic should be moved 10 degrees aft and left of the longitudinal axis to get maximum air up through the rotor system.
As the pilot lowers the collective in reaction to a loss of power during cruise flight there may be a tendency for the nose of the helicopter to pitch down. As a result, the pilot may tend to lean forward slightly, which delays the application of simultaneous aft cyclic to prevent the pitch change and associated loss of rotor rpm. A slight gain in altitude at cruise airspeed during the power off entry into an autorotation should not be of great concern as is the case for the execution of practice or actual quick stops.
Various accident investigations have concluded that, when faced with a real power failure at cruise airspeed, pilots are not simultaneously applying down collective, aft cyclic, and antitorque pedal inputs in a timely manner. Low inertia rotor systems store less kinetic energy during autorotation and, as a result, rotor rpm decays rapidly during deceleration and touchdown. Conversely, less energy is required to regain safe rotor rpm during autorotation entry and autorotative descent. The pilot should immediately apply simultaneous down collective, aft cyclic and trim the helicopter for entry into an autorotation initiated at cruise airspeed. If rotor rpm has been allowed to decrease, or has inadvertently decreased below acceptable limits, an application of aft cyclic may help rebuild rotor rpm. This application of aft cyclic must be made at least at a moderate rate and may be combined with a turn, either left or right, to increase airflow through the rotor system. This will work to increase rotor rpm. Care should be maintained to not over-speed the rotor system as this is attempted.
Risk Management during Autorotation Training
The following sections describe enhanced guidelines for autorotations during rotorcraft/helicopter flight training, as stated in Advisory Circular (AC) 61-140. There are risks inherent in performing autorotations in the training environment, and in particular the 180-degree autorotation. This section describes an acceptable means, but not the only means, of training applicants for a rotorcraft/helicopter airman certificate to meet the qualifications for various rotorcraft/helicopter ratings. You may use alternate methods for training if you establish that those methods meet the requirements of the Helicopter Flying Handbook (HFH), FAA practical test standards (PTS), and the Rotorcraft Flight Manual (RFM).
Straight-In Autorotation
A straight-in autorotation is one made from altitude with no turns. Winds have a great effect on an autorotation. Strong headwinds cause the glide angle to be steeper due to the slower groundspeed. For example, if the helicopter is maintaining 60 KIAS and the wind speed is 15 knots, then the groundspeed is 45 knots. The angle of descent will be much steeper, although the rate of descent remains the same. The speed at touchdown and the resulting ground run depend on the groundspeed and amount of deceleration. The greater the degree of deceleration, or flare, and the longer it is held, the slower the touchdown speed and the shorter the ground run. Caution must be exercised at this point as the tail rotor will be the component of the helicopter closest to the ground. If timing is not correct and a landing attitude not set at the appropriate time, the tail rotor may contact the ground causing a forward pitching moment of the nose and possible damage to the helicopter.
A headwind is a contributing factor in accomplishing a slow touchdown from an autorotative descent and reduces the amount of deceleration required. The lower the speed desired at touchdown, the more accurate the timing and speed of the flare must be, especially in helicopters with low-inertia rotor disks. If too much collective is applied too early during the final stages of the autorotation, the kinetic energy may be depleted, resulting in little or no cushioning effect available. This could result in a hard landing with corresponding damage to the helicopter. It is generally better practice to accept more ground run than a harder landing with minimal groundspeed. As proficiency increases, the amount of ground run may be reduced.
Technique (How to Practice)
Refer to Figure 3 (position 1).
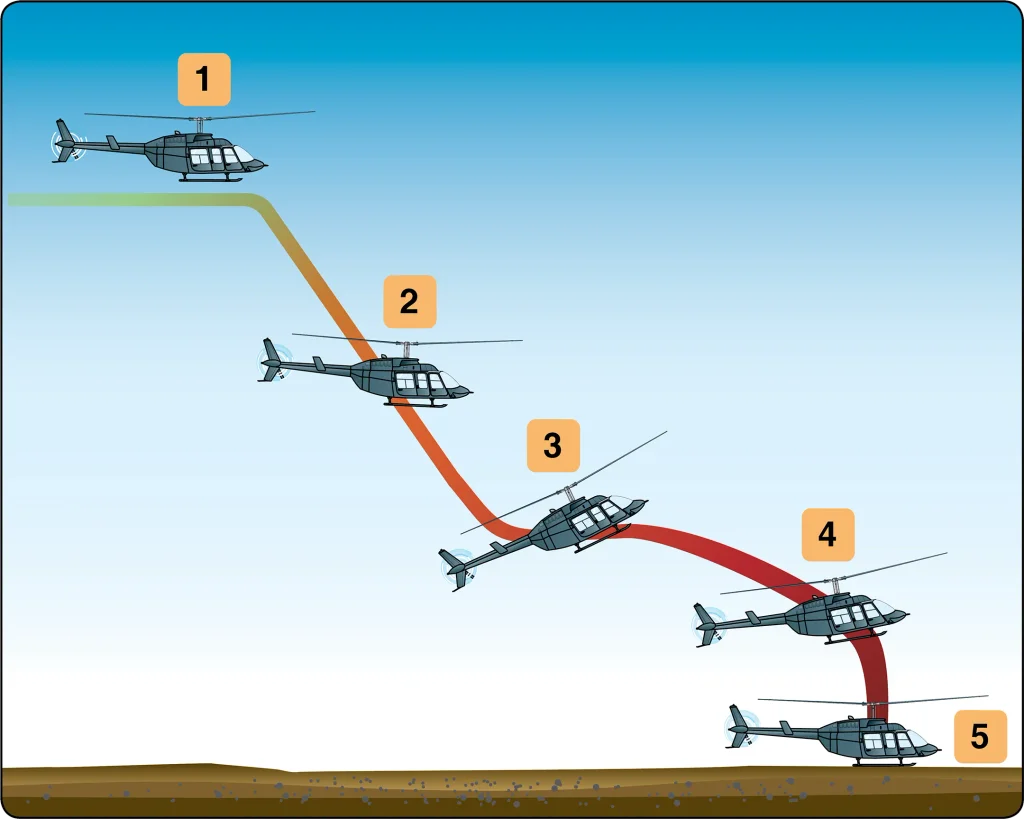
From level flight at the appropriate airspeed (cruise or the manufacturer’s recommended airspeed), 500–700 feet above ground level (AGL), and heading into the wind, smoothly but firmly lower the collective to the full down position. Use aft cyclic to prevent a nose low attitude while maintaining rotor rpm in the green arc with collective. If the collective is in the full down position, the rotor rpm is then being controlled by the mechanical pitch stops. During maintenance, the rotor stops must be set to allow minimum autorotational rpm with a light loading. This means that collective will still be able to be reduced even under conditions of extreme reduction of vertical loading (e.g., very low helicopter weight, at very low-density altitude). After entering an autorotation, collective pitch must be adjusted to maintain the desired rotor rpm.
Coordinate the collective movement with proper antitorque pedal for trim, and apply cyclic control to maintain proper airspeed. Once the collective is fully lowered, decrease throttle to ensure a clean split/separation of the needles. This means that the rotor rpm increases to a rate higher than that of the engine—a clear indication that the freewheeling unit has allowed the engine to disconnect. After splitting the needles, readjust the throttle to keep engine rpm above normal idling speed, but not high enough to cause rejoining of the needles. See the RFM for the manufacturer’s recommendations for autorotation rate of descent.
At position 2, adjust attitude with cyclic to obtain the manufacturer’s recommended autorotation (or best gliding) speed. Adjust collective as necessary to maintain rotor rpm in the lower part of the green arc. Aft cyclic movements cause an increase in rotor rpm, which is then controlled by a small increase in collective. Avoid a large collective increase, which results in a rapid decay of rotor rpm, and leads to “chasing the rpm.” Avoid looking straight down in front of the aircraft. Continually crosscheck attitude, trim, rotor rpm, and airspeed.
At the altitude recommended by the manufacturer (position 3), begin the flare with aft cyclic to reduce forward airspeed and decrease the rate of descent. Maintain heading with the antitorque pedals. During the flare, maintain rotor rpm in the green range. In the execution of the flare, care must be taken that the cyclic be moved rearward neither so abruptly that it causes the helicopter to climb, nor so slowly that it fails to arrest the descent, which may allow the helicopter to settle so rapidly that the tail rotor strikes the ground. In most helicopters, the proper flare attitude is that resulting in a groundspeed of a slow run. When forward motion decreases to the desired groundspeed—usually the lowest possible speed (position 4)—move the cyclic forward to place the helicopter in the proper attitude for landing.
This action gives the student an idea of airframe attitude to avoid, because a pilot should never allow ground contact unless the helicopter is more nose-low than that attitude. Limiting the flare to that attitude may result in slightly faster touchdown speeds but will eliminate the possibility of tail rotor impact on level surfaces.
The landing gear height at this time should be approximately 3–15 feet AGL, depending on the altitude recommended by the manufacturer. As the apparent groundspeed and altitude decrease, the helicopter must be returned to a more level attitude for touchdown by applying forward cyclic. Some helicopters can be landed on the heels in a slightly nose high attitude to help decrease the forward groundspeed, whereas others must land skids or landing gear level, in order to spread the landing loads equally to all of the landing gear. Extreme caution should be used to avoid an excessive nose high and tail low attitude below 10 feet. The helicopter must be close to the landing attitude to keep the tail rotor from contacting the surface.
At this point, if a full touchdown landing is to be performed, allow the helicopter to descend vertically (position 5). This collective application uses some of the kinetic energy in the rotor disk to help slow the descent rate of the helicopter. When the collective is raised, the opposite antitorque pedal used in powered flight will be needed due to the friction within the transmission/drive train. Touch down in a level flight attitude.
Control response with increased pitch angles will be slightly different than normal. With a decrease in main rotor rpm, the antitorque authority is reduced (the pedals react more slowly), requiring larger control inputs to maintain heading at touchdown.
Some helicopters, such as the Schweitzer 300, have a canted tail stabilizer. With a canted stabilizer, it is crucial that the pilot apply the appropriate pedal input at all times during the autorotation. If not the tailboom tends to swing to the right, which allows the canted stabilizer to raise the tail. This can result in a severe nose tuck which is quickly corrected with right pedal application.
A power recovery can be made during training in lieu of a full touchdown landing. Refer to the section on power recovery for the correct technique.
After the helicopter has come to a complete stop after touchdown, lower the collective pitch to the full-down position. Do not try to stop the forward ground run with aft cyclic, as the main rotor blades can strike the tail boom. By lowering the collective slightly during the ground run, an increase in weight is placed on the landing carriage, slowing the helicopter; however, this is dependent on the condition of the landing surface.
One common error is the holding of the helicopter off the surface, versus cushioning it onto the surface during an autorotation. Holding the helicopter in the air by using all of the rotor rpm kinetic energy usually causes the helicopter to have a hard landing, which results in the blades flexing down and contacting the tail boom. The rotor rpm should be used to cushion the helicopter on to the surface for a controlled, smooth landing instead of allowing the helicopter to drop the last few inches.
Common Errors
- Not understanding the importance of an immediate entry into autorotation upon powerplant or driveline failure.
- Failing to use sufficient antitorque pedal when power is reduced.
- Lowering the nose too abruptly when power is reduced, thus placing the helicopter in a dive.
- Failing to maintain proper rotor rpm during the descent.
- Applying up-collective pitch at an excessive altitude, resulting in a hard landing, loss of heading control, and possible damage to the tail rotor and main rotor blade stops.
- Failing to level the helicopter or achieve the manufacturers preferred landing attitude.
- Failing to minimize or eliminate lateral movement during ground contact. (Similar for items 8 and 9)
- Failing to maintain ground track in the air and keeping the landing gear aligned with the direction of travel during touchdown and ground contact.
- Failing (in a practice run) to go around if not within limits and specified criteria for safe autorotation.